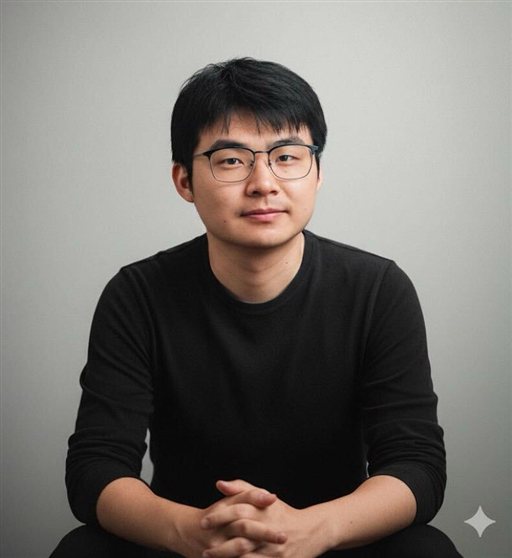
个人简介
邓豪博士现为中国科学院深圳先进技术研究院项目高级工程师(副高级)。2023年获中国科学院大学模式识别与智能系统博士学位,2015年获哈尔滨工业大学机械电子工程专业硕士学位。
研究聚焦机器人学与人机融合系统,重点关注可变形对象的机器人操作、灵巧抓取以及人机融合界面。提出了约束环境下可变形对象操作的统一物理建模与规划框架,深度参与开发了面向脑卒中瘫痪患者的上肢主动康复机器人系统、面向截肢患者的上肢可穿戴肌电灵巧型假肢手系统以及面向临床医患协作场景的口腔正畸诊疗系统和前列腺近距离粒子治疗系统等多套机器人软硬件,实现了康复及医疗场景下的精准智能化操作效能提升。主持在研广东省基础与应用基础研究基金、深圳市医学研究专项资金项目2项,作为核心成员全项目周期参与多项国家级、省市重点专项,包括国家重点研发计划、国家自然科学基金联合基金、广东省科技计划智能机器人专项、深圳市重大科技计划等领域重点项目10余项。发表领域内代表性期刊和旗舰会议论文20余篇;申请发明专利8项、授权4项,PCT专利申请4项、授权美国专利1项,登记软件著作权2项。
研究方向
- 可变形物体操作 — 约束环境下软体/弹性对象的物理建模、运动规划与控制
- 灵巧操作 — 多指灵巧手系统设计及其抓取控制
- 人机融合界面 — 无创神经交互控制、触觉感知与本体感觉重建
- 医疗机器人 — 康复机器人与多模态引导医疗操作系统
工作履历
- 项目高级工程师,中国科学院深圳先进技术研究院,2026年4月至今
- 工程师,中国科学院深圳先进技术研究院,2025年7月至2026年3月
- 研究方向:面向视觉障碍人群的灵巧假肢操作
- 博士后/助理研究员,中国科学院深圳先进技术研究院,2023年7月至2025年7月
- 合作导师:李光林
- 研究方向:多指灵巧手抓取操作规划与控制方法
- 研究助理,中国科学院深圳先进技术研究院,2016年1月至2017年8月
- PI:夏泽洋
- 研究方向:基于ROS的机器人系统开发、规划与控制
教育背景
- 博士,模式识别与智能系统,中国科学院大学,2023
- 学位论文:《面向可形变对象的机器人操作规划研究》
- 导师:夏泽洋/熊璟
- 硕士,机械电子工程,哈尔滨工业大学,2015
- 学位论文:《口腔正畸弓丝弯制系统路径规划与弯制控制的研究》
- 导师:刘守斌/夏泽洋(2014-2015,中国科学院深圳先进技术研究院)
- 学士,机械工程及自动化,武汉理工大学,2012
主持科研项目
- 深圳市医学研究专项资金项目,医疗辅助器械与试剂研制,“1.4mm级肺远端自主诊断超声纤维探头器械研制”,100万元,2027–2028
- 广东省基础与应用基础研究基金,粤港澳应用数学中心青年启动项目,“面向肺部精准立体定向放疗的自然呼吸物理建模与靶区实时预测方法”,5万元,2025–2027
- 中国科学院深圳先进技术研究院,青年创新促进会优秀青年基金,“双臂协同操作运动规划”,10万元,2016–2018
代表性论文
完整论文列表见 Google Scholar。
- Q. Wu, W. Hou, H. Deng, J. Xiong, Z. Xia. "Modeling Deformable Object under External Load with Reduced-State Representation." IEEE/ASME Transactions on Mechatronics, 2025. DOI
- T. Wang, L. Zhang, H. Deng, X. Wang, Q. Hu, X. Ma, X. Zhang, G. Li, P. Fang. "Preparation, Characterization, and Application Assessment for a Compound-structure Piezoelectret Combining Polypropylene and Fluorinated Polymers." Sensors and Actuators A: Physical, 393(16): 116774, 2025. DOI
- Z. Xia, F. Ahmad, H. Deng, L. Jiang, W. Qin, Q. Zhao, J. Xiong. "Robotics Application in Dentistry: A Review." IEEE Transactions on Medical Robotics and Bionics, 6(3): 851–867, 2024. DOI
- S. He, J. Shen, B. Zhang, F. Ahmad, H. Deng, X. Li, J. Xiong, Z. Xia. "A Material Point-based Simulation Method for Soft Robots with Free Boundary Interactions." Robotica, pp. 1–14, 2024. DOI
- H. Deng, F. Ahmad, J. Xiong, Z. Xia. "A Robot-Object Unified Modeling Method for Deformable Object Manipulation in Constrained Environments." IEEE/ASME Transactions on Mechatronics, 2024. DOI
- 邓豪, 熊璟, 夏泽洋. "一种用于可形变对象操作的动力学模型隐式求解方法". 机器人, 2024, 46(1): 45-53. DOI
- J. Xiong, C. Fu, K. Ibrahim, H. Deng, Z. Xia. "A Mechanism-Image Fusion Approach to Calibration of an Ultrasound-Guided Dual-Arm Robotic Brachytherapy System." IEEE/ASME Transactions on Mechatronics, 26(6): 3211–3220, 2021. DOI
- 邓豪, D. G. K. Madusanka, 熊璟, 夏泽洋. "用于手部运动功能康复的纤维强化型并联腔道式软体驱动器设计" 高技术通讯, 31(3): 270–278, 2021.
- Z. Xia, H. Deng, S. Weng, Y. Gan, J. Xiong, H. Wang. "Development of a Robotic System for Orthodontic Archwire Bending." IEEE International Conference on Robotics and Automation (ICRA), Stockholm, Sweden, pp. 730–735, 2016.
- H. Deng, Z. Xia, S. Weng, Y. Gan, J. Xiong, Y. Ou, J. Zhang. "Motion Planning and Control of a Robotic System for Orthodontic Archwire Bending." IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Hamburg, Germany, pp. 3729–3734, 2015. DOI