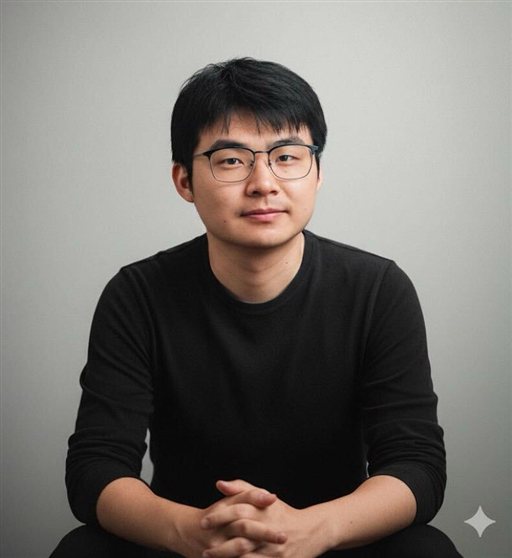
Biography
Dr. Hao Deng is currently an Associate Professor at the Shenzhen Institutes of Advanced Technology (SIAT), Chinese Academy of Sciences. He received his Ph.D. in Pattern Recognition and Intelligent Systems from the University of Chinese Academy of Sciences in 2023, and his M.S. in Mechatronic Engineering from Harbin Institute of Technology in 2015.
His research focuses on robotics and human–machine integration systems, with particular emphasis on robotic manipulation of deformable objects, dexterous grasping, and human–machine interaction interfaces. He proposed a unified physics-based modeling and planning framework for deformable object manipulation in constrained environments, and has contributed extensively to the development of multiple robotic hardware and software systems, including an upper-limb active rehabilitation robot for stroke patients, a wearable EMG-driven dexterous prosthetic hand for amputees, a dual-arm robotic system for orthodontic treatment, and a prostate brachytherapy system. These works have delivered enhanced precision and intelligence in rehabilitation and medical scenarios. He serves as Principal Investigator of two ongoing funded projects: the Guangdong Basic and Applied Basic Research Foundation and the Shenzhen Medical Research Fund. Serving as a core member, he took part in more than ten research projects from initiation through final completion, including the National Key R&D Program, the NSFC grants, major project of Guangdong S&T Dept. on Intelligent Robotics, and the Shenzhen S&T Program. He has published over 20 papers; he has filed 8 invention patents (4 granted), 4 PCT applications (1 U.S. patent granted), and registered 2 software copyrights.
Research Interests
- Deformable Object Manipulation — physics-based modeling, motion planning, and control of soft/deformable objects in constrained environments
- Dexterous Manipulation — system design and grasping control of multi-fingered dexterous hands
- Human–Machine Interaction Interfaces — non-invasive neural interaction control, tactile sensing, and proprioception reconstruction
- Medical Robotics — rehabilitation robots and multimodal-guided medical operation systems
Experience
- Associate Professor, Shenzhen Institutes of Advanced Technology, CAS, Apr. 2026 to Present
- Assistant Professor, Shenzhen Institutes of Advanced Technology, CAS, Jul. 2025 to Mar. 2026
- Research: dexterous prosthetic manipulation for the visually impaired
- Postdoctoral Researcher / Assistant Research Fellow, Shenzhen Institutes of Advanced Technology, CAS, Jul. 2023 to Jul. 2025
- Supervisor: Prof. Guanglin Li
- Research: grasping manipulation planning and control methods for multi-fingered dexterous hands
- Research Assistant, Shenzhen Institutes of Advanced Technology, CAS, Jan. 2016 to Aug. 2017
- PI: Prof. Zeyang Xia
- Research: ROS-based robotic system development, planning and control
Education
- Ph.D. in Pattern Recognition and Intelligent Systems, University of Chinese Academy of Sciences, 2023
- Dissertation: Planning for Robotic Manipulation of Deformable Objects
- Supervisors: Prof. Zeyang Xia / Prof. Jing Xiong
- M.S. in Mechatronic Engineering, Harbin Institute of Technology, 2015
- Thesis: Research on Path Planning and Bending Control of an Orthodontic Archwire Bending System
- Supervisors: Prof. Shoubin Liu / Prof. Zeyang Xia (2014–2015, Shenzhen Institutes of Advanced Technology, CAS)
- B.S. in Mechanical Engineering and Automation, Wuhan University of Technology, 2012
Research Projects
- Shenzhen Medical Research Fund, "Development of 1.4 mm Autonomous Diagnostic Ultrasonic Fiber Probe for Distal Lung Lesions," RMB 1,000,000, 2027–2028
- Guangdong Basic and Applied Basic Research Foundation, Youth Startup Program, "Physical Modeling of Free-Breathing Respiration and Real-Time Target Prediction Method for Precision Lung Stereotactic Body Radiotherapy," RMB 50,000, 2025–2027
- Distinguished Young Scholars Fund, Youth Innovation Promotion Association, SIAT, CAS, "Motion Planning for Dual-Arm Manipulation," RMB 100,000, 2016–2018
Selected Publications
A full list is available on Google Scholar.
- Q. Wu, W. Hou, H. Deng, J. Xiong, and Z. Xia. "Modeling Deformable Object under External Load with Reduced-State Representation." IEEE/ASME Transactions on Mechatronics, 2025. DOI
- T. Wang, L. Zhang, H. Deng, X. Wang, Q. Hu, X. Ma, X. Zhang, G. Li, and P. Fang. "Preparation, Characterization, and Application Assessment for a Compound-structure Piezoelectret Combining Polypropylene and Fluorinated Polymers." Sensors and Actuators A: Physical, 393(16): 116774, 2025. DOI
- Z. Xia, F. Ahmad, H. Deng, L. Jiang, W. Qin, Q. Zhao, and J. Xiong. "Robotics Application in Dentistry: A Review." IEEE Transactions on Medical Robotics and Bionics, 6(3): 851–867, 2024. DOI
- S. He, J. Shen, B. Zhang, F. Ahmad, H. Deng, X. Li, J. Xiong, and Z. Xia. "A Material Point-based Simulation Method for Soft Robots with Free Boundary Interactions." Robotica, pp. 1–14, 2024. DOI
- H. Deng, F. Ahmad, J. Xiong, and Z. Xia. "A Robot-Object Unified Modeling Method for Deformable Object Manipulation in Constrained Environments." IEEE/ASME Transactions on Mechatronics, 2024. DOI
- H. Deng, J. Xiong, and Z. Xia. "An Implicit Solution to the Dynamic Model for Deformable Object Manipulation." ROBOT, 46(1): 45–53, 2024. DOI
- J. Xiong, C. Fu, K. Ibrahim, H. Deng, and Z. Xia. "A Mechanism-Image Fusion Approach to Calibration of an Ultrasound-Guided Dual-Arm Robotic Brachytherapy System." IEEE/ASME Transactions on Mechatronics, 26(6): 3211–3220, 2021. DOI
- H. Deng, D. G. K. Madusanka, J. Xiong, and Z. Xia. "Design of a Fiber-reinforced Parallel Cavity-type Soft Actuator for Hand Movement Function Rehabilitation." High Technology Letters, 31(3): 270–278, 2021.
- Z. Xia, H. Deng, S. Weng, Y. Gan, J. Xiong, and H. Wang. "Development of a Robotic System for Orthodontic Archwire Bending." In Proceedings of the IEEE International Conference on Robotics and Automation (ICRA), Stockholm, Sweden, pp. 730–735, 2016.
- H. Deng, Z. Xia, S. Weng, Y. Gan, J. Xiong, Y. Ou, and J. Zhang. "Motion Planning and Control of a Robotic System for Orthodontic Archwire Bending." In Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Hamburg, Germany, pp. 3729–3734, 2015. DOI